Spurdog
moos-ivp-spurdog
The autonomy and control toolbox that runs the Spurdog, built on MOOS-IvP: sensor and modem drivers, state estimation, vehicle control, health monitoring, simulation and mission management. Apart from the aft-section control applications, it does not assume a particular vehicle.
MOOS-IvP
The open-source autonomy middleware the Spurdog software is built on: MOOS, a publish-subscribe middleware for robotic applications, and the IvP Helm, a behavior-based helm for multi-objective decision making, with tools for simulation, visualization and mission planning.

pymoos2
Write MOOS-IvP applications in Python. pymoos2 speaks the MOOSDB wire
protocol, so a Python app runs under pAntler beside C++ apps, appears in
uMAC and pMarineViewer with a full AppCast, and reads its configuration
from the same .moos file.
MagCalCockpit
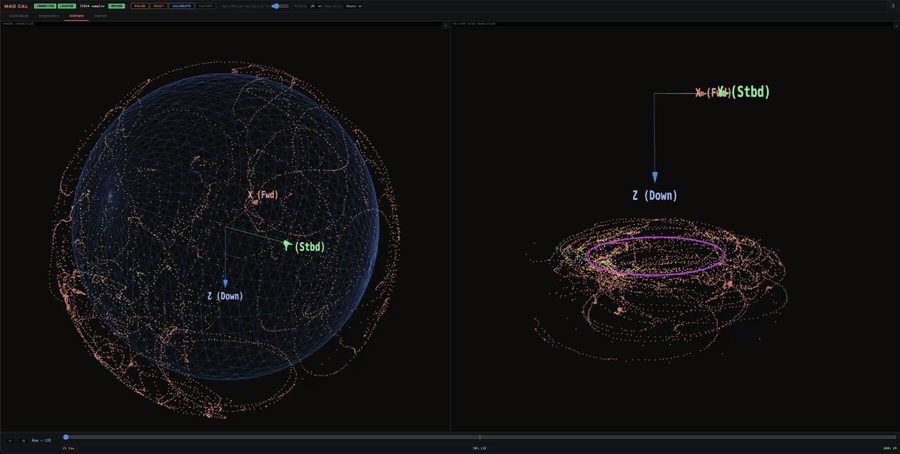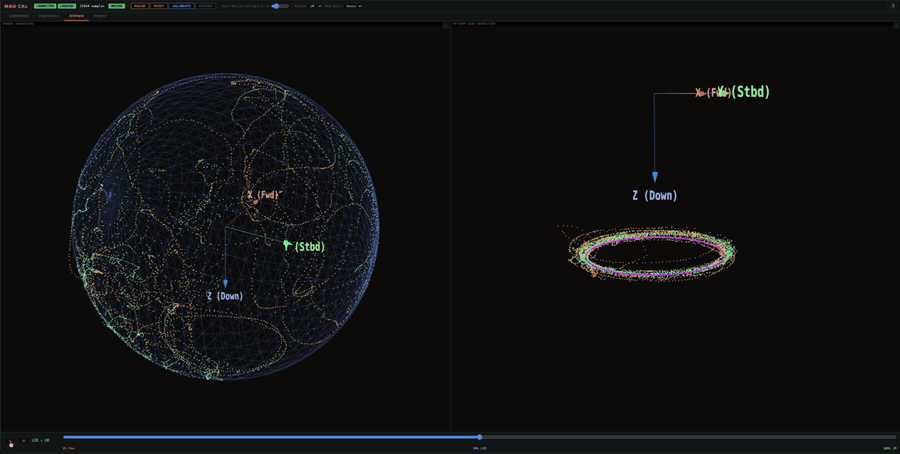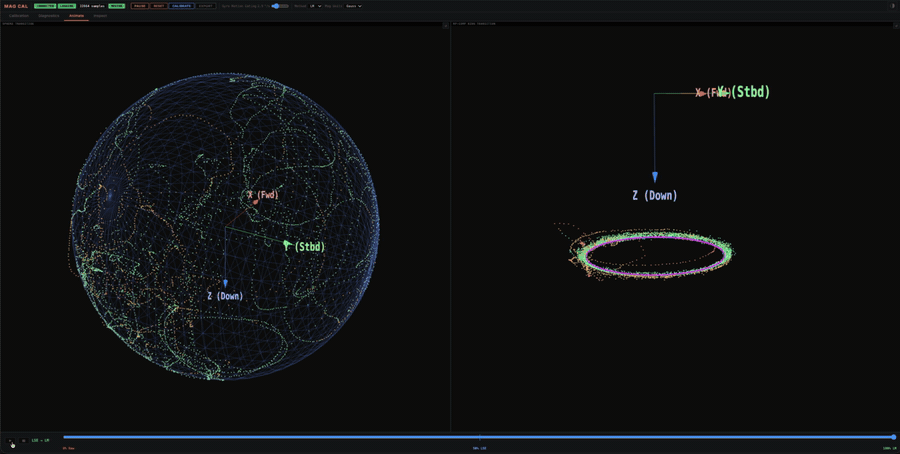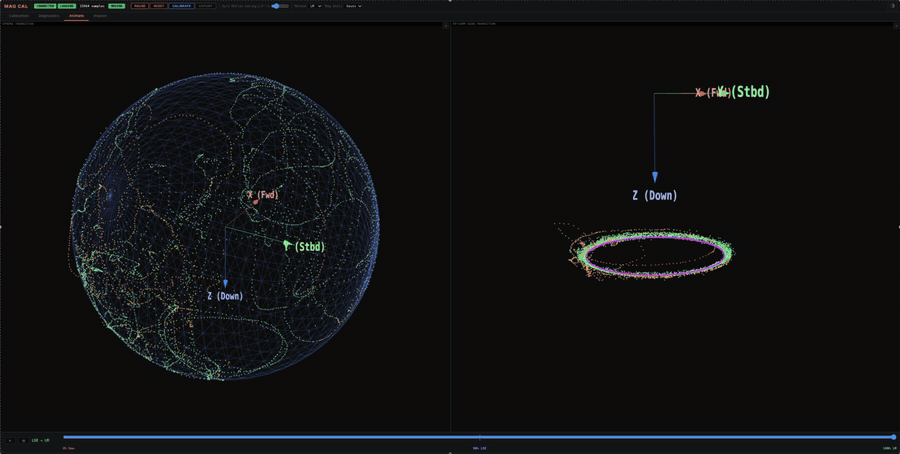
Real-time magnetometer calibration. A live display guides the operator through the motion and shows which orientations are still missing; sessions can be trimmed, inspected and reopened. Any AHRS can feed it over a 13-field UDP packet.
navigator-cpp
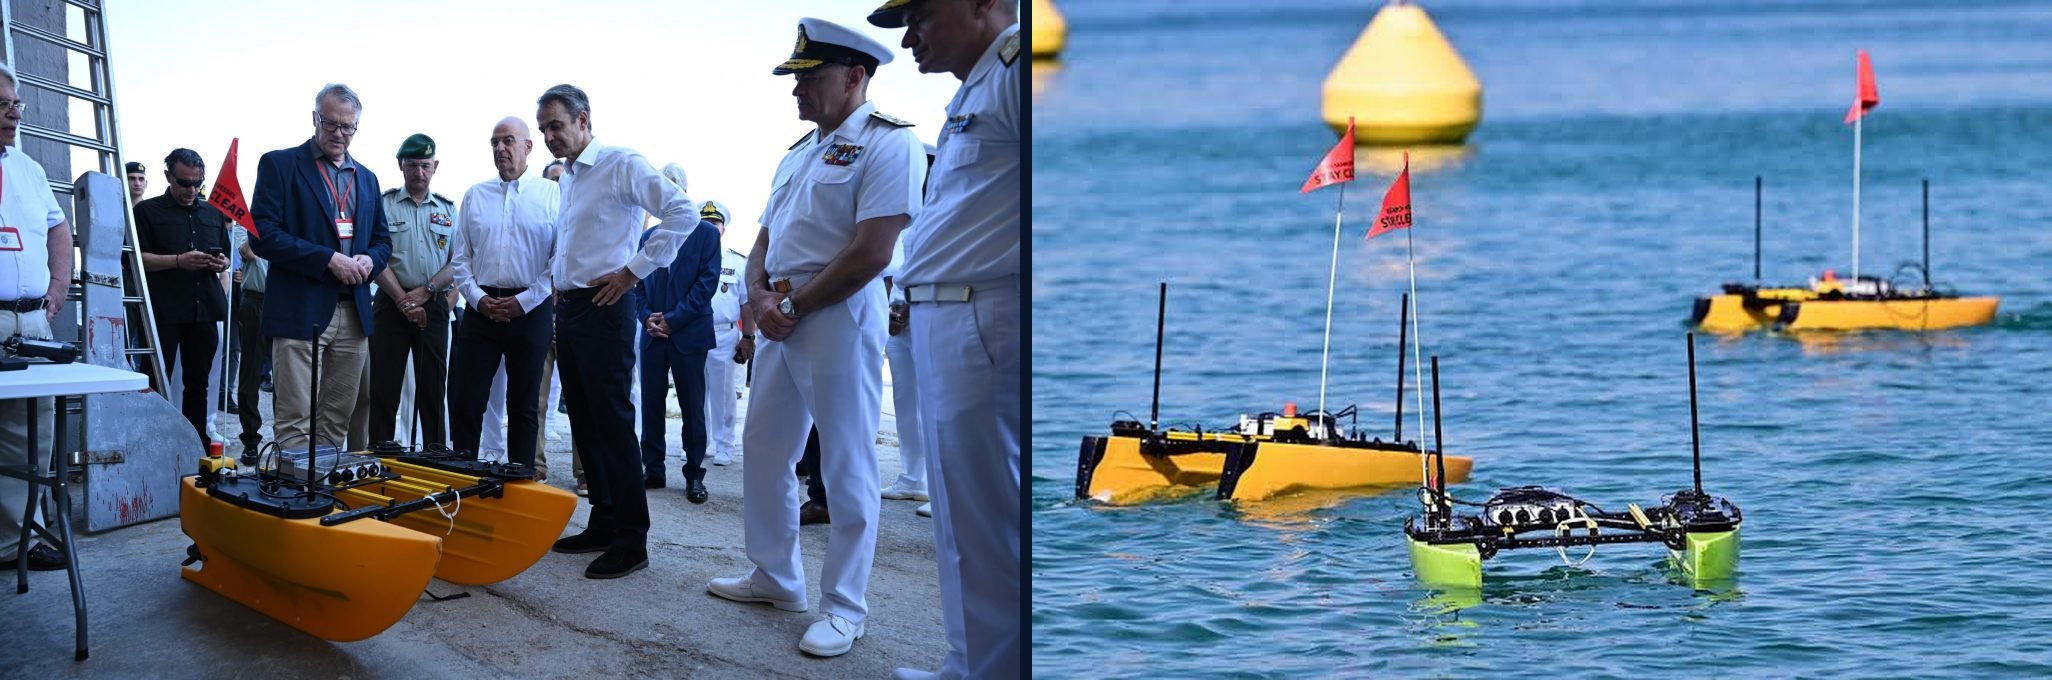
A C++ hardware interface library for the Blue Robotics Navigator flight controller: IMU, magnetometers, barometer, ADC, PWM, LEDs and RC input, over direct I2C, SPI and GPIO. It detects Navigator V1 or V2 and Raspberry Pi 4 or 5 at runtime.
Third Party
moos-ivp-spurdog-gander
An extension of moos-ivp-spurdog maintained by Gander Robotics, Inc. It builds on the moos-ivp-spurdog libraries and adds applications, behaviors and missions alongside them.