September 2026
Commercial License to Gander Robotics
The Spurdog AUV has been commercially licensed to Gander Robotics Inc. to provide a commercial option for the Spurdog AUV and ecosystem.
September 2026
First Flight of the Six-Inch Variant
First flight of the six-inch Spurdog variant, which is under development.
August 2026
Spurdog Deployment with Upgraded Navigation
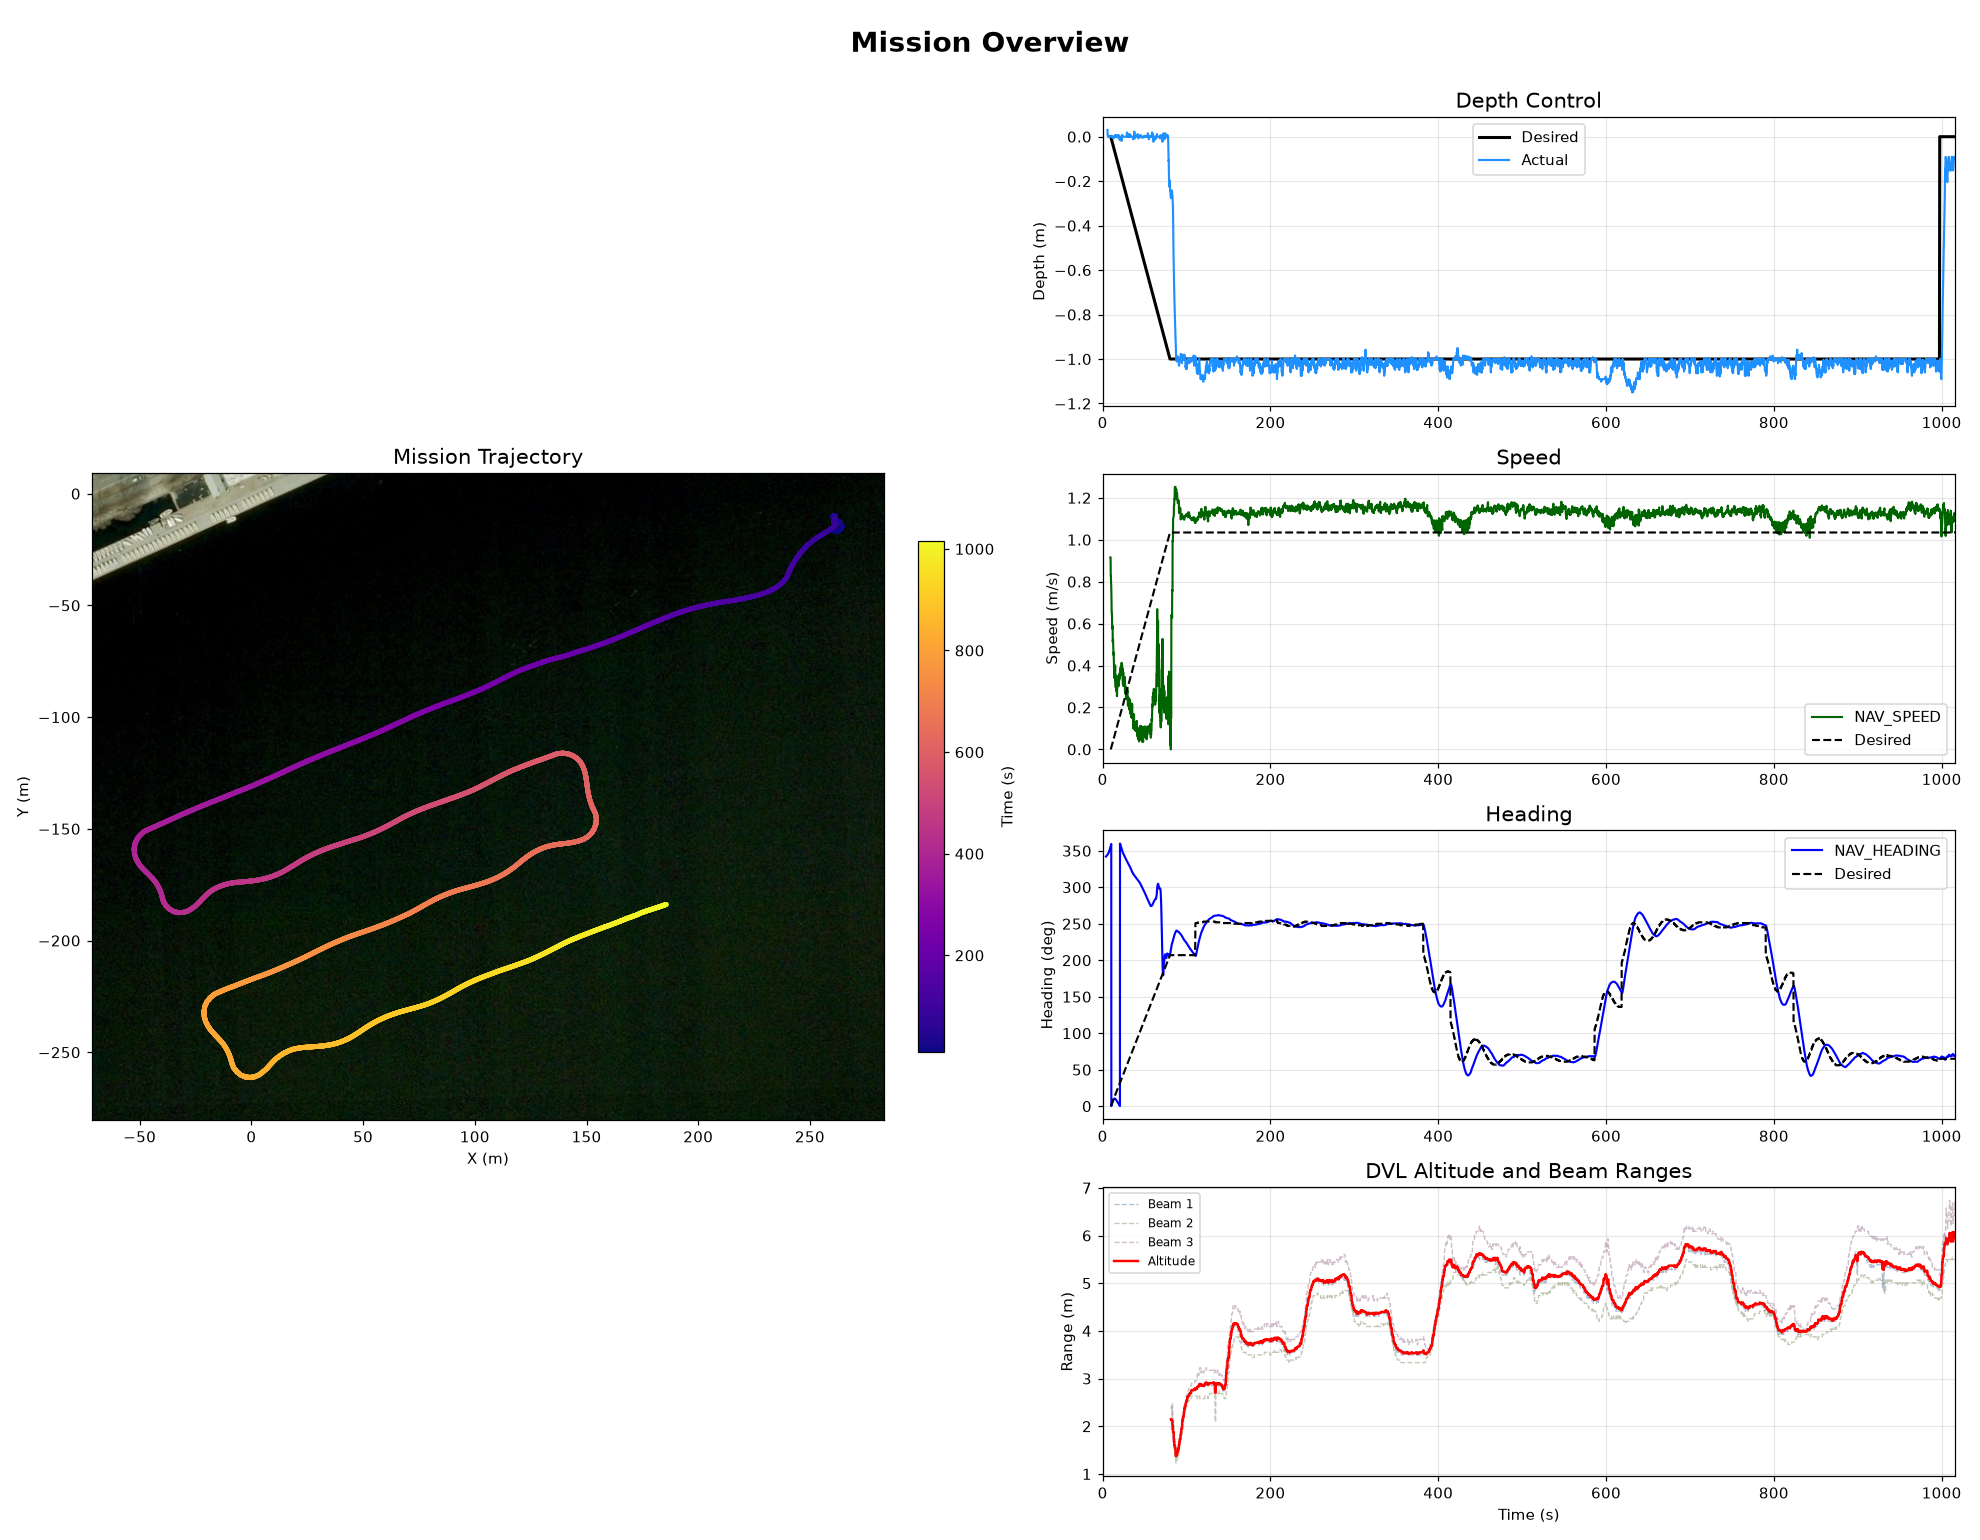
A Spurdog deployment with upgraded navigation achieved 3.5 m of surfacing error after a 1.04 km submerged deployment, measured as the difference between the INS and the NEO-M9N GNSS (about 2 m CEP) at surfacing. The system data and logs can be downloaded from the Documentation page. The fine eye may catch, that the controller was solely under feedforward for speed, and the vehicle was on a fresh charge.
June 2026
Two AUVs Navigate Cooperatively While Submerged
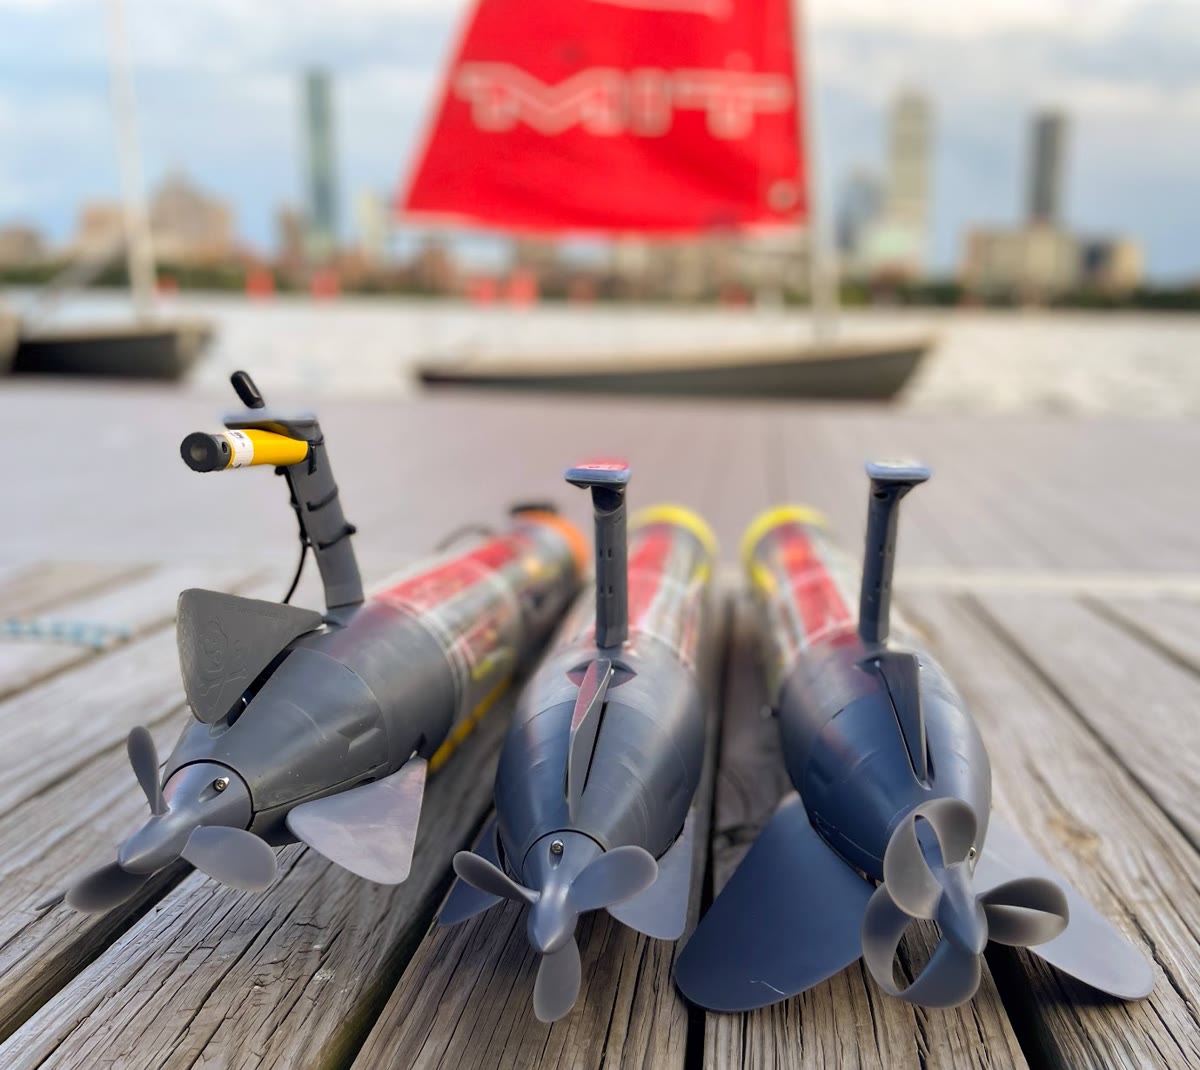
Two Spurdog AUVs operated fully submerged at the same time on the Charles River, exchanging live inter-vehicle acoustic ranges and building a joint factor graph online to reach roughly 1.3 m of terminal position error in a GNSS-denied environment.
May 2026
Website Launch
The Spurdog project website and collaborator portal are now live.
January 2026
Vehicle Tested to 400 Meters
Vehicle design updated and tested to 400 meters depth at DeepTech at Woods Hole Oceanographic Institution.
October 2025
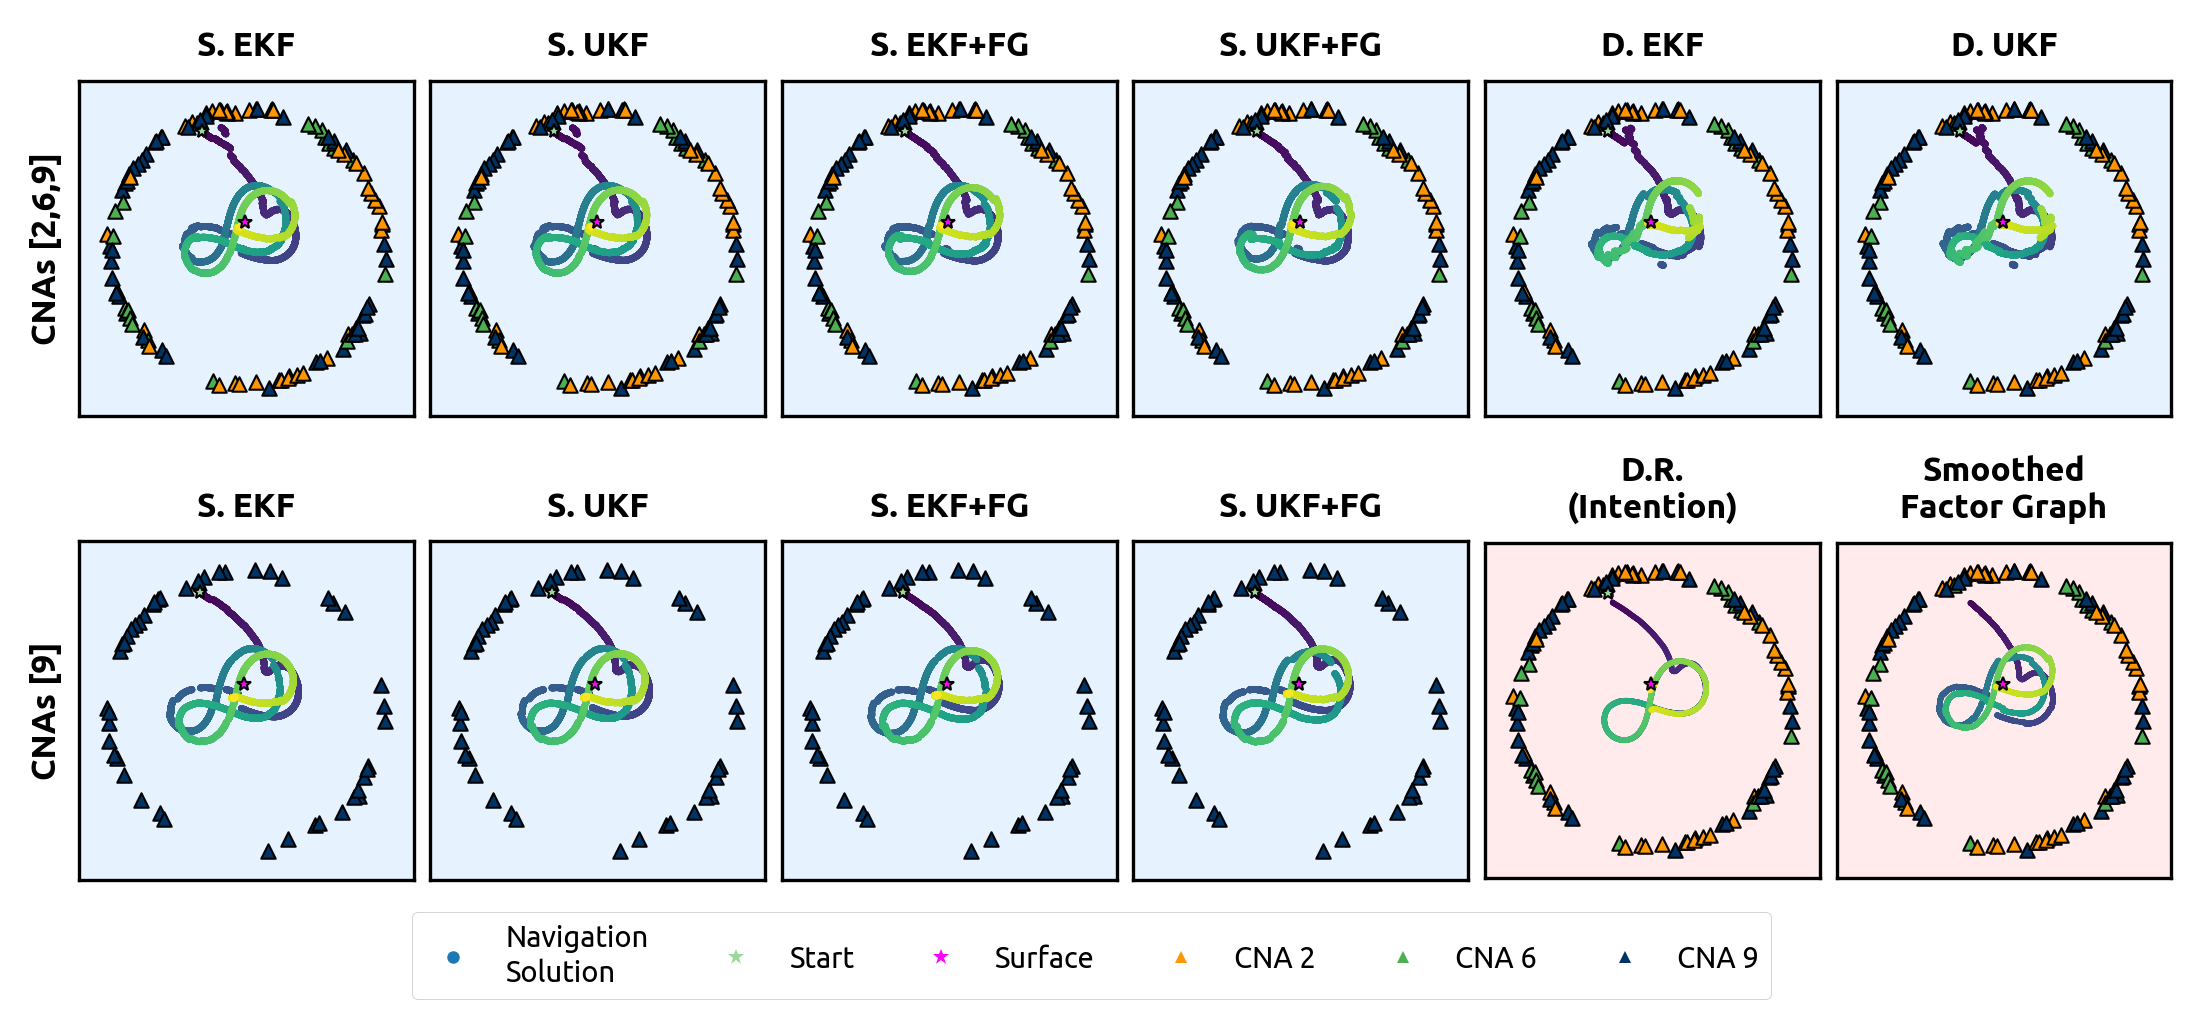
ASV-Aided AUV Navigation at IROS 2025
A field study on the Charles River demonstrated autonomous surface vehicles acting as mobile acoustic references to bound the drift of a submerged Spurdog, presented at the IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) 2025.
September 2025
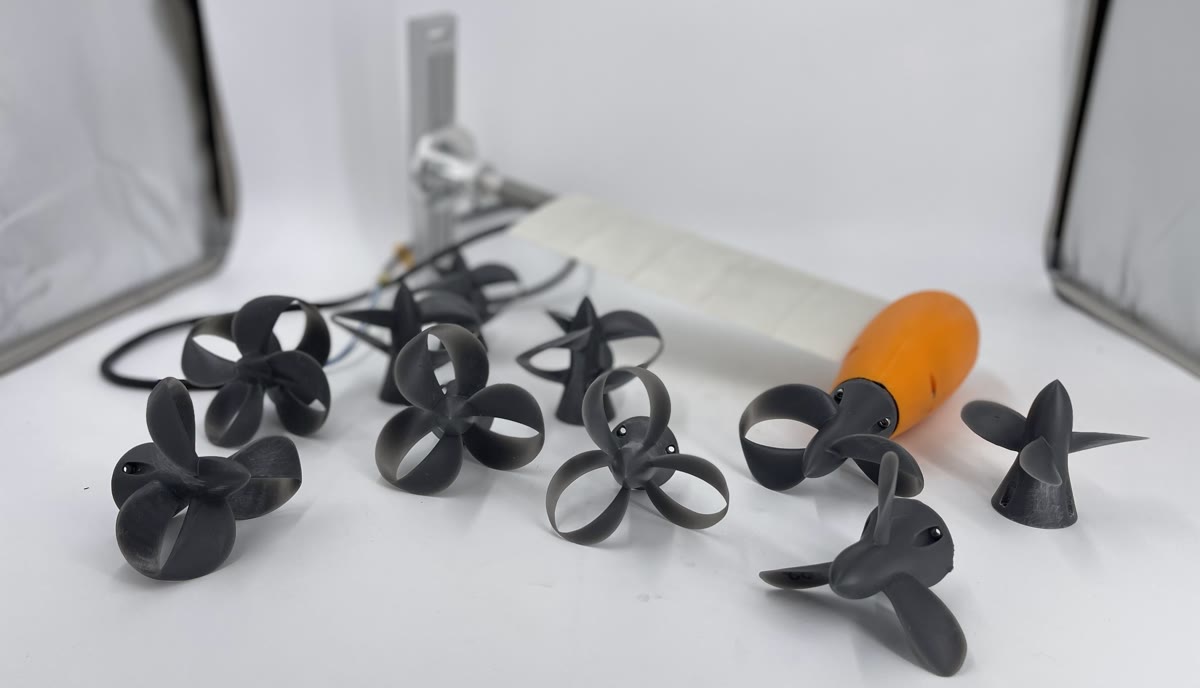
Toroidal Propeller Study at OCEANS 2025
A study characterizing 3D-printed toroidal propellers against conventional OpenProp designs on the Spurdog platform, measured at the MIT Sea Grant tow tank, was presented at OCEANS 2025.
September 2024
Modular Trident Tailcone at OCEANS 2024
The Trident series of tailcones — a modular, field-configurable three-axis aft section fielded across multiple AUV platforms — was presented at OCEANS 2024 in Halifax.
September 2024
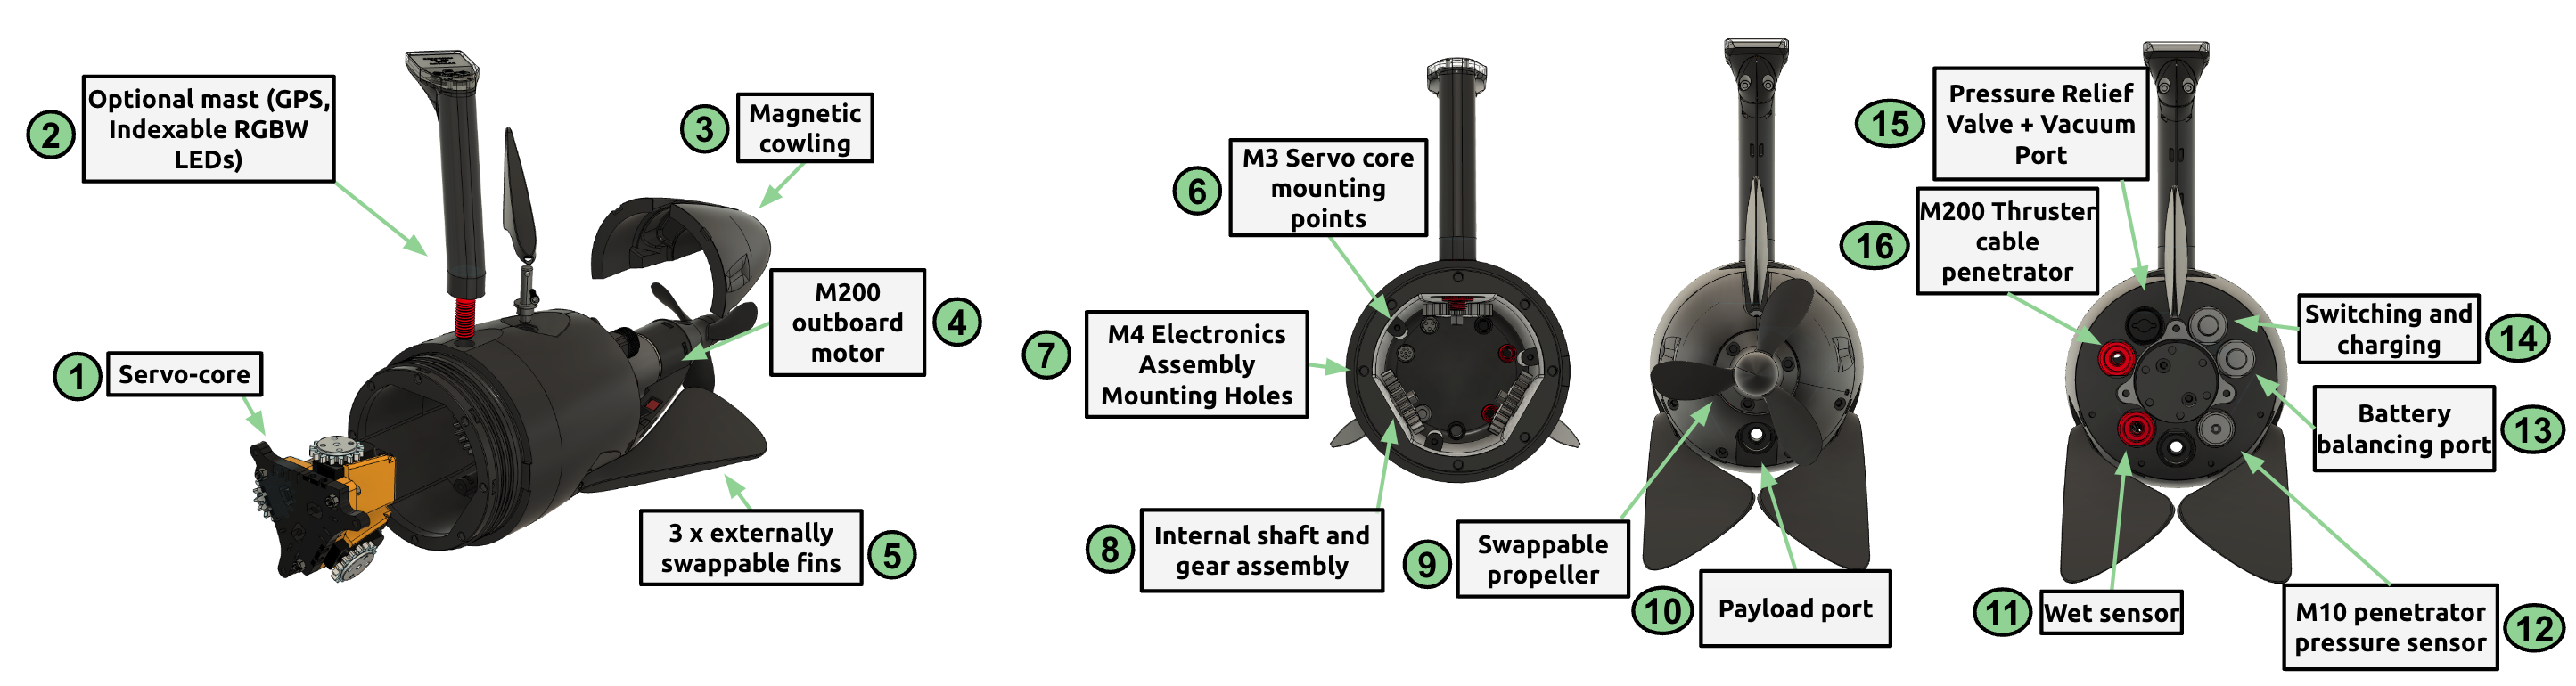
Spurdog Platform Paper at IEEE/OES AUV 2024
The Spurdog AUV — a low-cost, field-configurable platform built from commercial and 3D-printed parts — was introduced at the IEEE/OES Autonomous Underwater Vehicles Symposium (AUV) 2024.
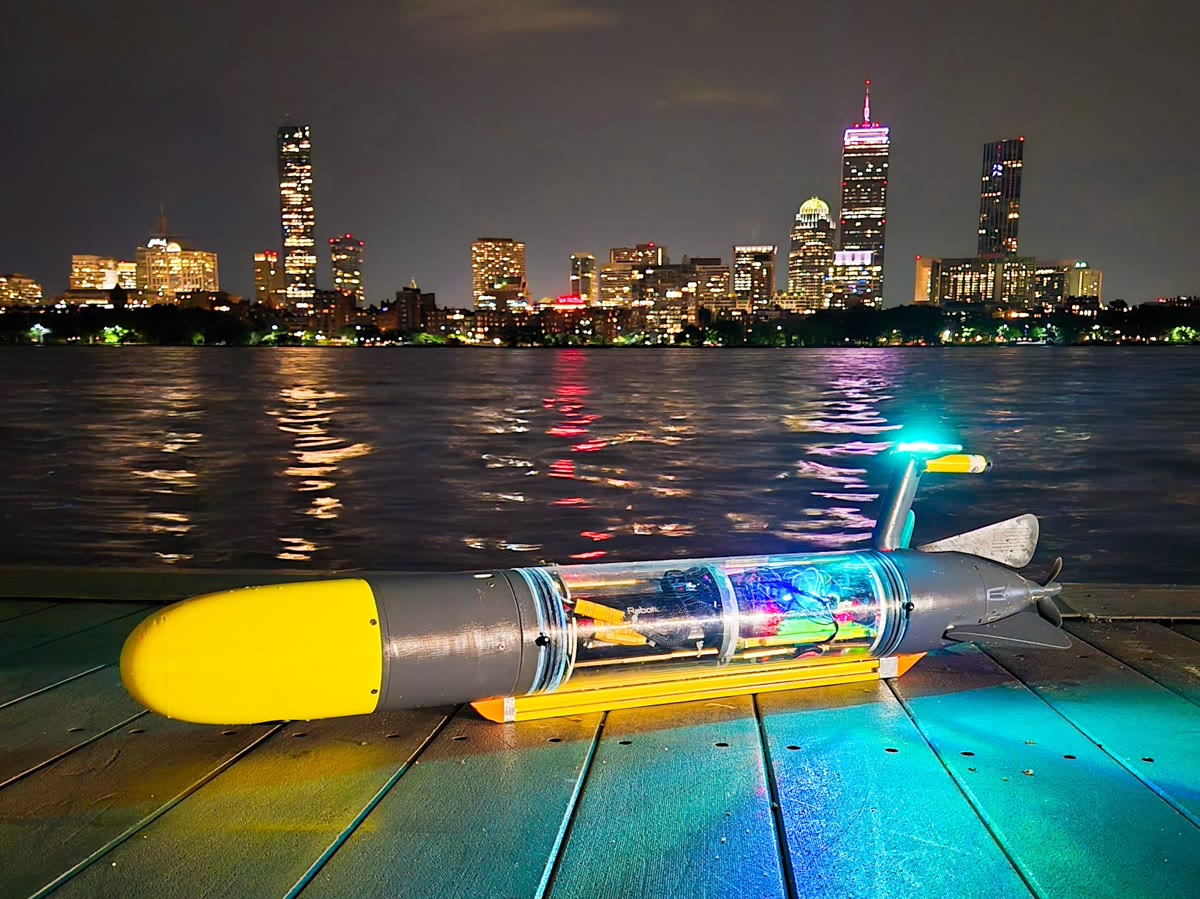
April 30, 2024
First Flight
Spurdog's first deployment and swim test.